|
Yiyu Wang I'm an undergraduate student at Shanghai Jiao Tong University (B.S. in Mechanical Engineering) and at the University of Michigan, Ann Arbor (B.S. in Computer Science, second bachelor's). I work in the Robotics Autonomy and Planning Lab with Prof. Zhongqiang (Richard) Ren, in the Scalable Spatial Intelligence Lab with Prof. Yulun Tian, and in the Advanced Agent-Robotics Technology Lab at Carnegie Mellon University with Prof. Katia Sycara, where I also collaborate with Prof. Yaqi Xie and Bowen Li. I work on planning and agentic systems for robots. I am interested in how embodied agents can carry out long-horizon tasks: planning over what they know, learning and refining their own skills, and keeping a memory of the world they act in. Before this, I worked on search-based planning for heterogeneous multi-robot systems. I am actively looking for research internships, and for a Ph.D. position in robotics, computer science, or related fields starting in Fall 2027. |

|

News[Jun 2026] Our paper on min-max constrained heterogeneous multi-robot routing was accepted to IROS 2026, and the solver is released on PyPI as PyRCH. [May 2026] I joined the Advanced Agent-Robotics Technology Lab at Carnegie Mellon University, advised by Prof. Katia Sycara. [Oct 2025] The HEHA preprint is on arXiv. [Sep 2025] Our paper HEHA was accepted to the IEEE International Symposium on Multi-Robot and Multi-Agent Systems (MRS 2025) as a poster paper. [Aug 2025] I started my second bachelor's in Computer Science at the University of Michigan and joined the Scalable Spatial Intelligence Lab. [Aug 2024] I joined the Robotics Autonomy and Planning Lab, advised by Prof. Zhongqiang (Richard) Ren. Earlier newsResearchI am interested in planning and agentic systems for robots, robot learning, world models, and long-horizon manipulation and whole-body tasks, as well as how multiple agents should be organized to work together. My earlier work used heuristic search to plan routes and exploration for teams of physically different robots. Ongoing projects
Publications
|
|
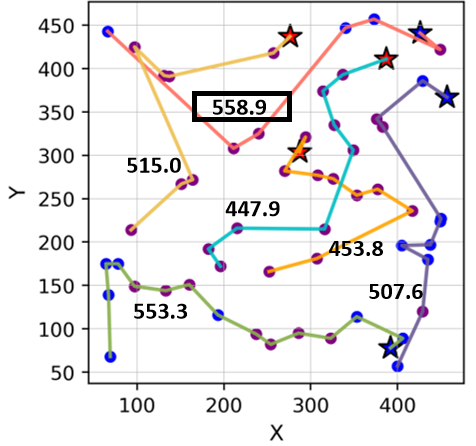
Algorithms and Solvers for Min-Max Constrained Heterogeneous Multi-Robot Routing Problems
Yiyu Wang, Yunxiang Yao, Shizhe Zhao, Zhongqiang Ren IROS, 2026 paper to be released / package website / solver demo An anytime focal-search solver for min-max heterogeneous multi-robot routing under capacity, resource, and time-window constraints, implemented in C++ and released as the PyRCH Python package. |
|
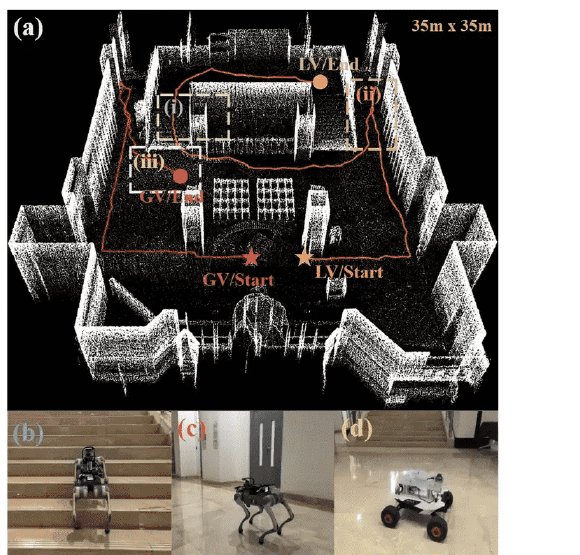
HEHA: Bounded Suboptimal Planning for Constrained Routing and Its Use in Heterogeneous Multi-Robot Exploration of Unknown Environments
Longrui Yang†, Yiyu Wang†, Jingfan Tang†, Yunpeng Lv, Shizhe Zhao, Chao Cao, Zhongqiang Ren † Equal contribution IEEE T-RO, conditionally accepted, 2026 MRS Poster Paper, 2025 paper / demo Path planning for autonomous exploration of an unknown environment by drones, wheeled, and legged robots with different terrain-traversal capabilities. HEHA splits the problem into global routing, solved by a bounded-suboptimal anytime focal search that minimizes the makespan under traversability constraints, and a heterogeneity-aware local planner that avoids duplicated exploration. |
Miscellanea |
Software |
PyRCH — a Python package wrapping our C++ anytime
focal-search solver for heterogeneous multi-agent routing.
pip install PyRCH
Solver demo |
Teaching |
Grader, EECS 498 (Bayesian Machine Learning), University of Michigan.
Teaching Assistant, ME2110J (Introduction to Solid Mechanics), Shanghai Jiao Tong University. |
Services |
Delegated reviewer, IEEE Robotics & Automation Letters (RA-L).
Reviewer, IROS 2026. |
|
Thanks to Jon Barron for the website template. |